

 Electronic Community Mechanical Community OSHWLab JLCPCB JLC3DP JLCCNC JLCMC JLCONE EasyEDA JLCCAN LCSC Cable LCSC Panel

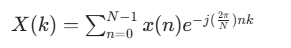
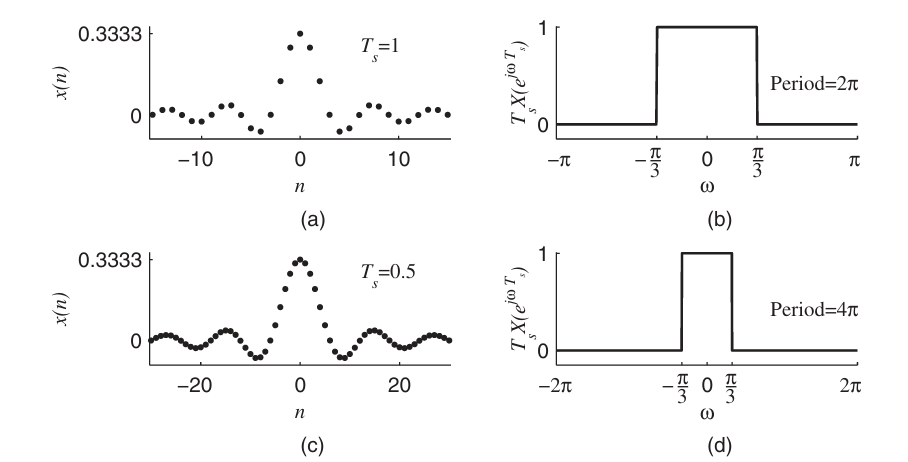
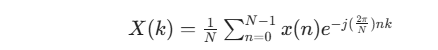
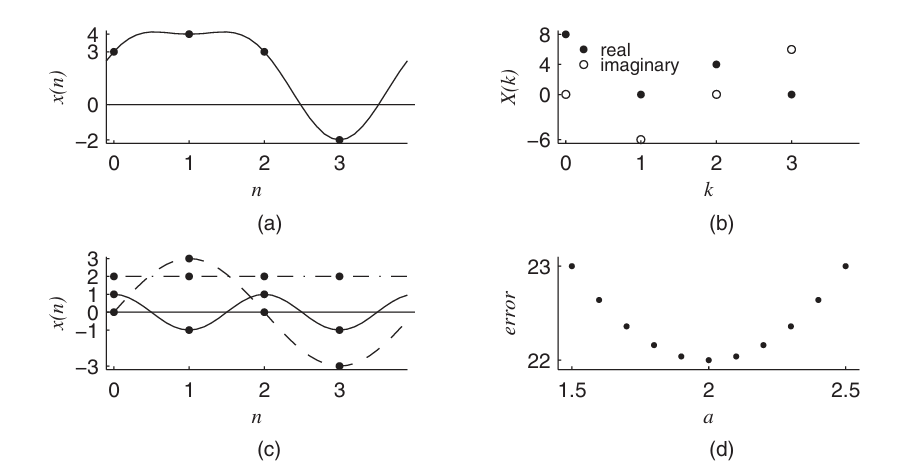
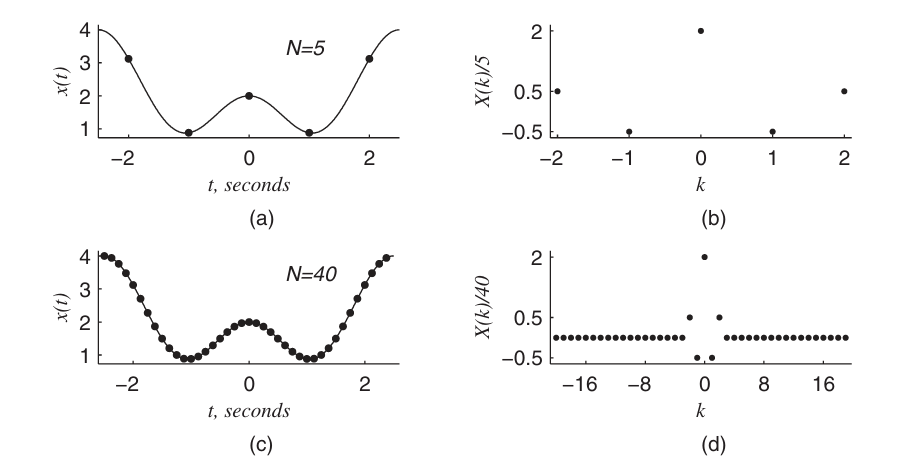
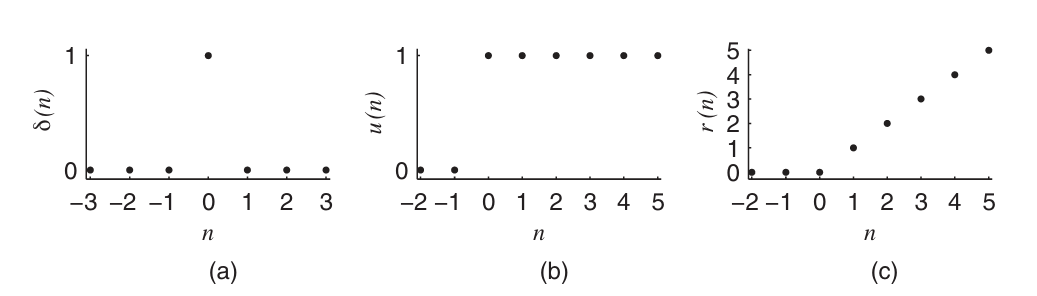
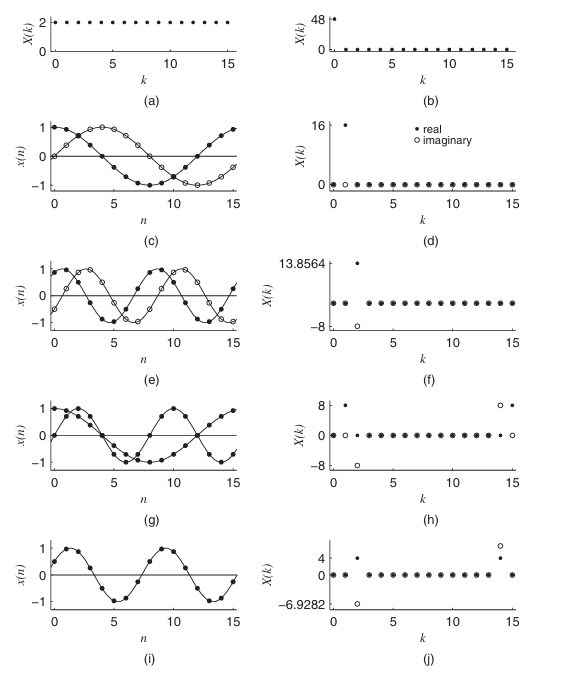
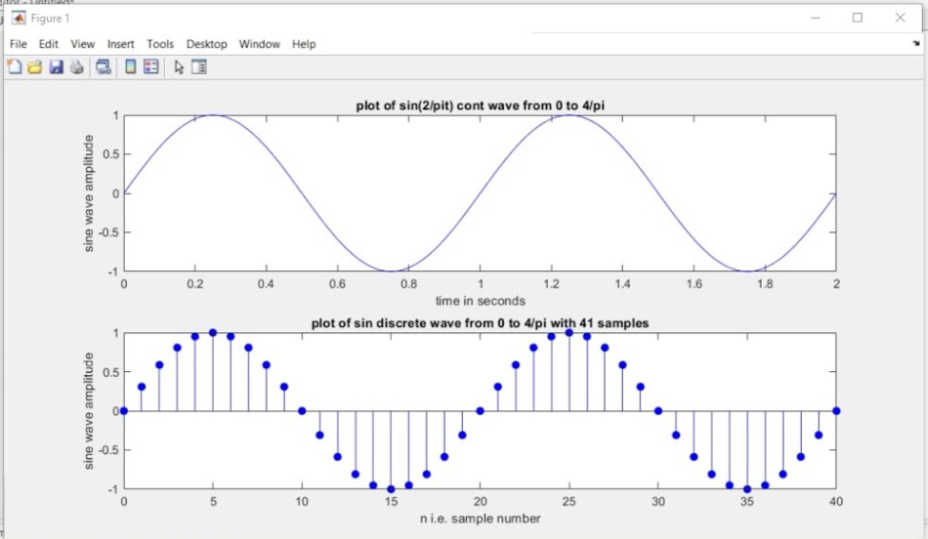
 , is the simplest signal in discrete signal analysis. It is defined precisely in my text as:
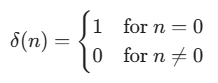
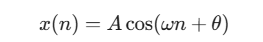
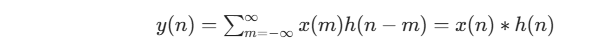
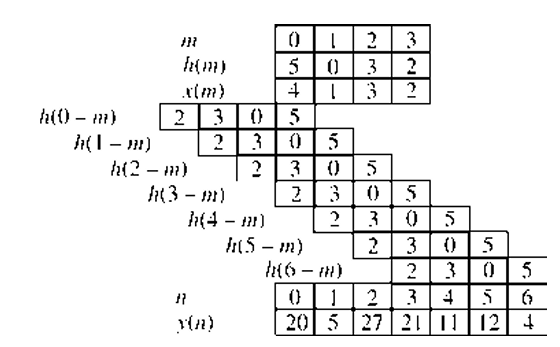
In CNC machining, most design discussions focus on dimensions, tolerances, hole positions, thread depth, and surface finish. Those are obviously important, but many assembly and handling problems begin somewhere much smaller. The edge condition of a part, especially around holes and contact features, often decides whether a machined component feels clean and well-made or awkward and troublesome in real use.
This is one reason small edge features deserve more attention during design review. A part can be dimensionally correct and still create unnecessary problems if the entrance to a hole is too sharp, if burrs remain around a cut feature, or if repeated assembly quickly damages an untreated edge. These issues are easy to dismiss during CAD work because they do not look dramatic on the model. In production and assembly, they show up immediately.
A sharp hole entrance is a good example. On paper, the hole diameter may be perfect. In practice, a screw may start poorly, a pin may catch at the edge, or an operator may need to force the part into position. Once that happens, the edge is more likely to chip, deform, or raise a burr. The result is not just an ugly entrance. It becomes an assembly problem, and people often blame the fit or the tolerance before they look at the edge itself.
This is especially common on threaded holes, locating holes, and repeated-use features. A threaded hole may technically be correct, but if the entrance condition is rough or too sharp, fastener starting becomes less consistent. A locating pin may fit once but damage the hole mouth after repeated installation. On parts that are assembled and disassembled many times, the edge condition becomes part of the product’s real durability.
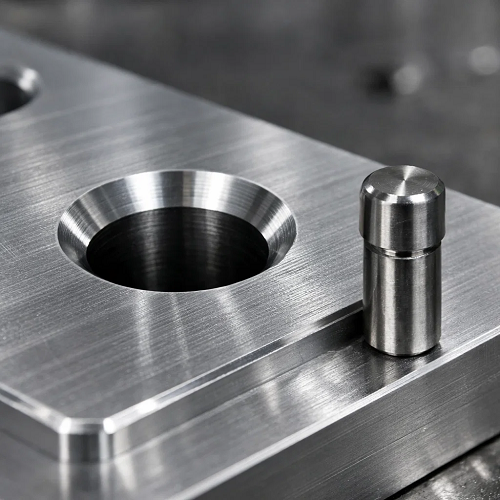
That is why controlled edge preparation matters. In many CNC parts, a very small edge treatment can reduce a much larger downstream problem. It may help guide entry, protect the feature during handling, reduce burr-related interference, and make the part feel more deliberate in assembly. This is not just about appearance. It is about how the part behaves.
The same principle applies to outer edges. A part does not need razor-sharp corners to be considered precise. In fact, sharp untreated corners are often less practical. They chip more easily, feel rougher in handling, and may create avoidable safety concerns during assembly or inspection. A controlled break at the edge often improves the part without affecting the design intent in any negative way.
Of course, not every edge needs the same treatment. Some edges only need a light break to remove sharpness. Others are functionally important and need a more deliberate feature to support alignment or entry. This is where machining knowledge becomes valuable. If every edge is treated casually, important features may remain under-controlled. If every edge is over-specified, cost and machining time go up without adding much value.
For designers and buyers, the practical question is not whether every part needs aggressive edge treatment. The real question is which edges affect function and which ones simply need to stop being sharp. Hole entrances, thread starts, locating features, and repeated assembly areas usually deserve more attention than random exterior corners.
This is also where communication on the drawing matters. General notes such as “break sharp edges” can be useful, but they are not always enough when the edge geometry affects assembly. A controlled entry feature should be treated differently from a casual deburred corner. If the edge is doing real work, the print should make that clear.
A good example of this thinking can be seen in the way chamfers are used on machined parts. A chamfer may look like a very small detail, but it often improves entry, protects edges, and reduces assembly frustration in ways that are easy to underestimate. A more detailed explanation of that topic can be found in this guide on chamfer in CNC machining: purpose, angles, applications, and drawing guide.
The broader lesson is simple. Small edge features are often treated like secondary details, but many of them influence how a part is actually used. In CNC machining, the difference between a part that merely passes inspection and a part that assembles cleanly, handles well, and lasts longer is sometimes found in those details.
When edge condition is reviewed early, many downstream problems become easier to prevent. Burrs are easier to control. Hole entry becomes smoother. Threads start more cleanly. Handling damage is reduced. Repeated assembly becomes more consistent. None of that changes the headline dimensions of the part, but it changes the real quality of the result.
For that reason, edge treatment should not be treated as an afterthought. It should be considered as part of how the design functions in production and in use. Small features often carry more value than they appear to on the drawing.
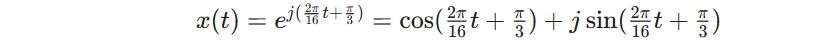
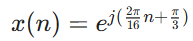
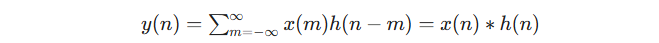
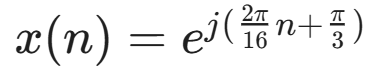
Designing the RCIN Port for Radio Control
The RCIN port is where your radio receiver connects to the flight system. This port faces very unique hardware challenges because it is frequently exposed to external elements and varying voltage levels from different receiver brands.
1. Absolute Input Protection with Zener Diodes
External modules are a primary source of hardware destruction. If a user accidentally injects a 5V power source into an RX pin that operates strictly at 3.3V, the event will permanently destroy the microcontroller.
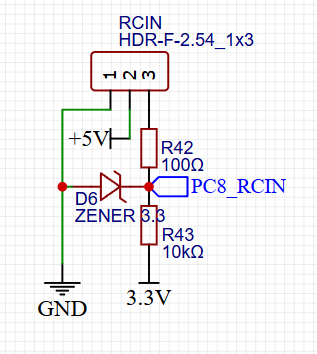
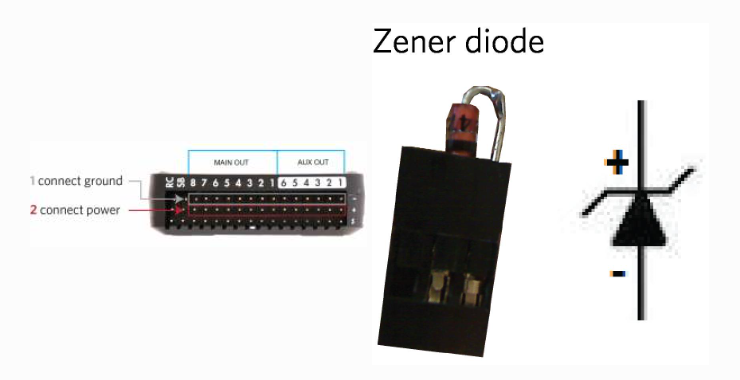
To mitigate this catastrophic risk, I designed a dedicated hardware protection circuit on the RCIN header using a 10kOhm resistor, a 100 Ohm resistor, and a Zener diode. The Zener diode is placed in a reverse bias configuration between the signal line and Ground.
A Zener diode is a unique semiconductor that acts like a voltage pressure relief valve. During normal 3.3V operation, this diode is completely invisible to the signal. However, if a voltage spike exceeding 3.3V enters the pin, the Zener diode instantly activates and clamps the voltage, safely routing the dangerous excess energy straight to Ground. The 100 Ohm resistor acts as a current limiter to protect the diode from burning out, while the 10kOhm resistor provides a stable bias state.
For a deep academic explanation of how Zener diodes protect logic circuits, you can check on this website: Electronics Tutorials: Zener Diodes.
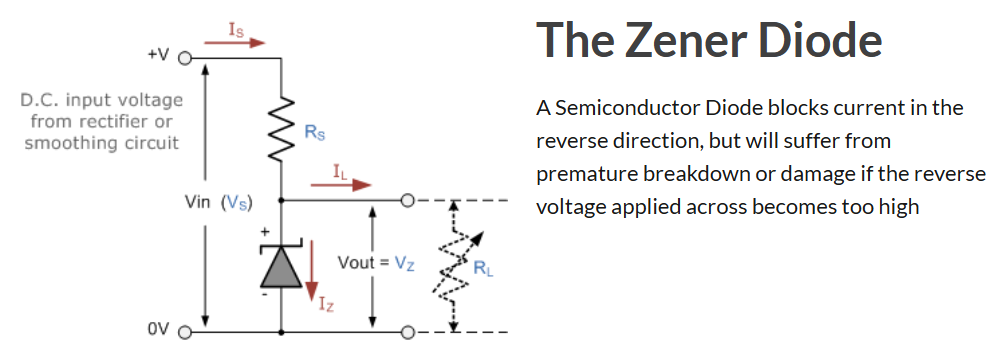
This images shown exactly how the diode is placed in parallel with the working load to clamp incoming voltage.)
2. The SBUS Inversion Advantage on the STM32H7
Legacy radio protocols like SBUS present a unique schematic challenge because SBUS is an inverted serial protocol. On a standard UART signal, an idle line is held HIGH and drops LOW to send data. SBUS does the exact opposite. On older generation Flight Controllers utilizing STM32F4 processors, hardware designers were forced to add complex external NPN transistor circuits to physically invert the signal before it reached the MCU.
However, my Flight Controller utilizes the exceptionally powerful STM32H7 processor. The STM32H7 features advanced internal UART peripherals that support direct hardware inversion via software configuration. Because of this, my schematic no longer requires an external logic inverter IC on the RCIN port. The raw inverted signal travels safely through our Zener protection network directly into the MCU. This saves valuable board space and reduces the number of components that could potentially fail in the air.
Software Integration via ArduPilot
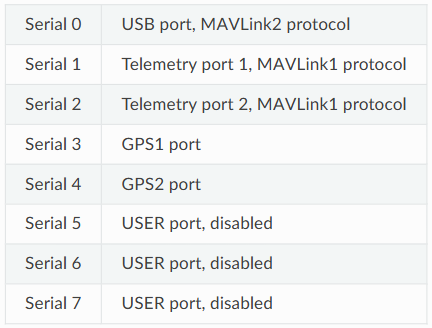
Once the hardware is designed securely, we must configure the software to utilize these physical ports. Within ArduPilot firmware, every UART we route on the PCB is assigned a specific SERIAL number.
For the TELEME port, you must alter the SERIALx_PROTOCOL parameter in your Mission Planner software to activate MAVLink communication. For the RCIN port receiving the SBUS signal, we must command the STM32H7 processor to activate its internal hardware inverter. We accomplish this by modifying the SERIALx_OPTIONS parameter. By setting the correct bitmask, the processor will handle the SBUS inversion internally without any flaws.
You can check on this website for the official ArduPilot documentation regarding how to configure those specific serial options: ArduPilot Serial Options Documentation.
For a stunning visual explanation regarding how to design a UART hardware interface from start to finish, you can see in this video from Phil's Lab on YouTube: https://youtu.be/aVUqaB0IMh4?si=xleHFRQrn2qTWUUw
Conclusion
Designing the communication ports on a Flight Controller requires much more than simply drawing wires between component pins. By implementing proper 10uF and 100nF power filtering, utilizing 22 Ohm resistors for signal integrity, and designing a Zener diode network for absolute voltage protection, we guarantee that the drone will never lose connection to the pilot. Furthermore, leveraging the internal inversion capabilities of the STM32H7 processor allows us to create a much cleaner and more reliable circuit board.
Today, we are going to look specifically at the TELEME and RCIN blocks in my schematic. I will explain in detail how to design UART ports that are exceptionally robust. This design not only protects your microcontroller from physical electrical damage but also guarantees flawless data communication with your Radio Control receiver and your high power LoRa telemetry modules.
UART
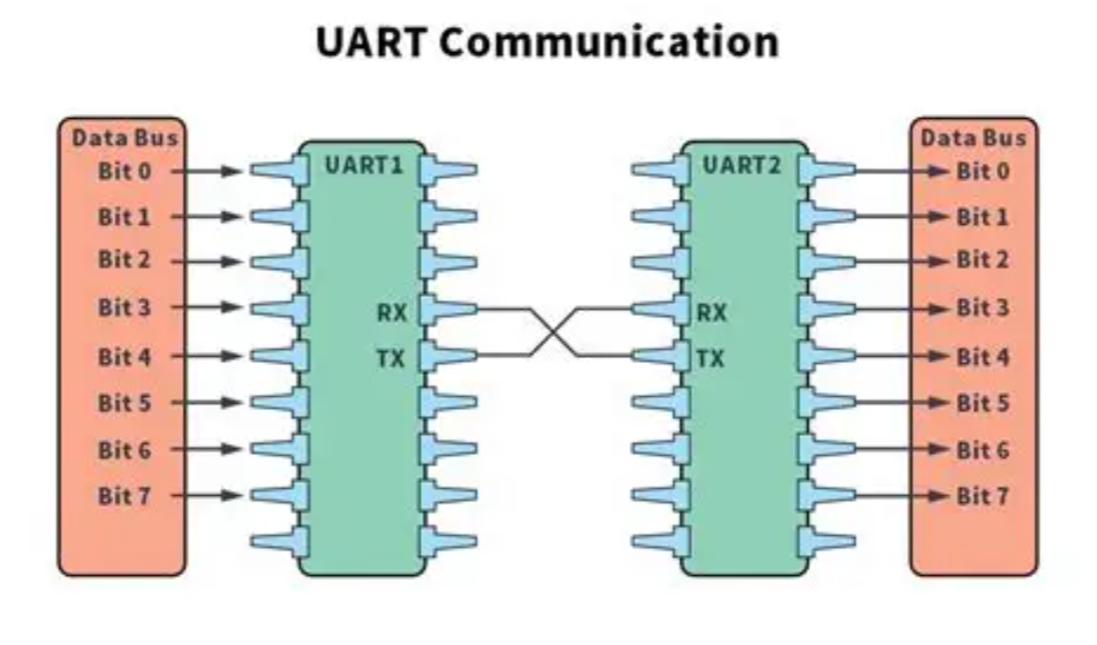
Before we dissect the specific ports on the board, we must understand the underlying protocol. UART stands for Universal Asynchronous Receiver Transmitter. This protocol relies on two primary data lines, which are TX for Transmit and RX for Receive. When you connect any external module to the Flight Controller, you must always cross these communication lines. The TX pin of the external module connects to the RX pin of the Flight Controller, and the same rule applies in reverse.
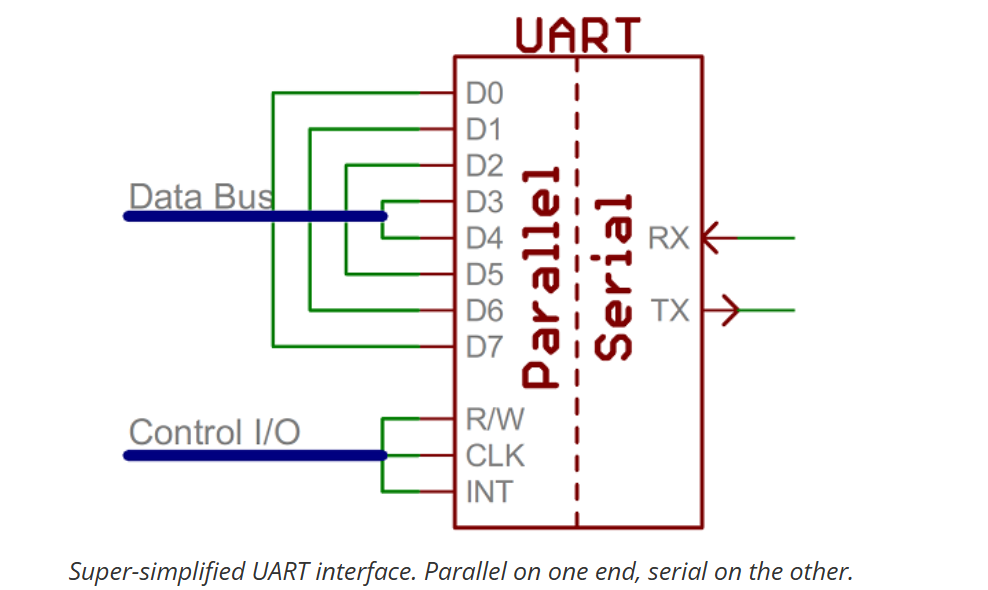
If you want to understand the fundamental mechanics of serial communication at the hardware level, you can check on this website from SparkFun: SparkFun Serial Communication Tutorial. They offer a highly trusted explanation regarding how digital data packets are constructed and transmitted.
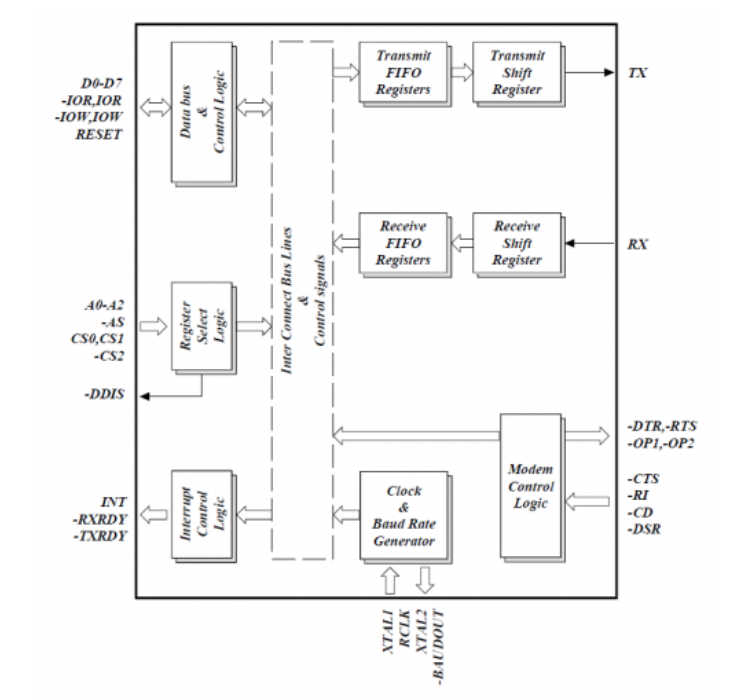
This images shown exactly how the internal shift registers handle the raw serial data stream.
Designing the TELEME Port for LoRa Telemetry
The TELEME port on my Flight Controller is designed specifically to connect to external radio telemetry modules. These modules are frequently high power LoRa radios that constantly broadcast flight data back to a laptop on the ground. Designing this port requires strict attention to power delivery stability and digital signal integrity.
1. Power Stability and Capacitive Filtering
Telemetry radios draw massive surges of current when they transmit data packets. If you power a 1 Watt radio directly from the same 5V line as your main MCU without adequate filtering, the rapid voltage drops will cause the microcontroller to reboot mid flight.
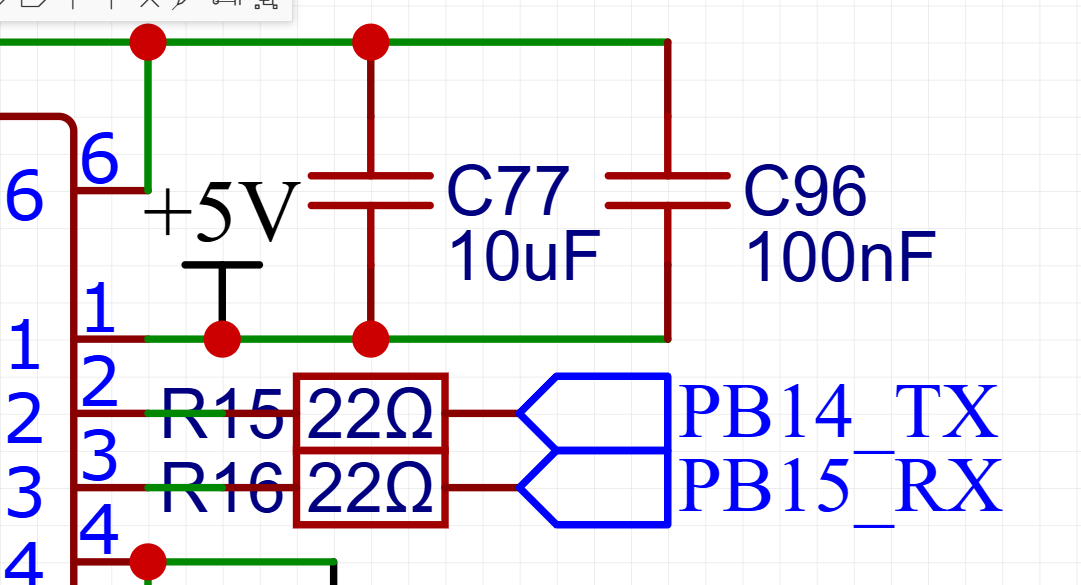
In my schematic, I ensure the TELEME port features a highly robust filter network. I implemented a 10uF bulk capacitor paired with a 100nF ceramic decoupling capacitor, placing both exactly next to the telemetry power pin. The 10uF capacitor acts as a localized energy reservoir to absorb the sudden current draw, while the 100nF capacitor actively filters out high frequency electrical noise. This combination guarantees the power plane remains absolutely stable.
2. Signal Integrity with 22 Ohm Resistors
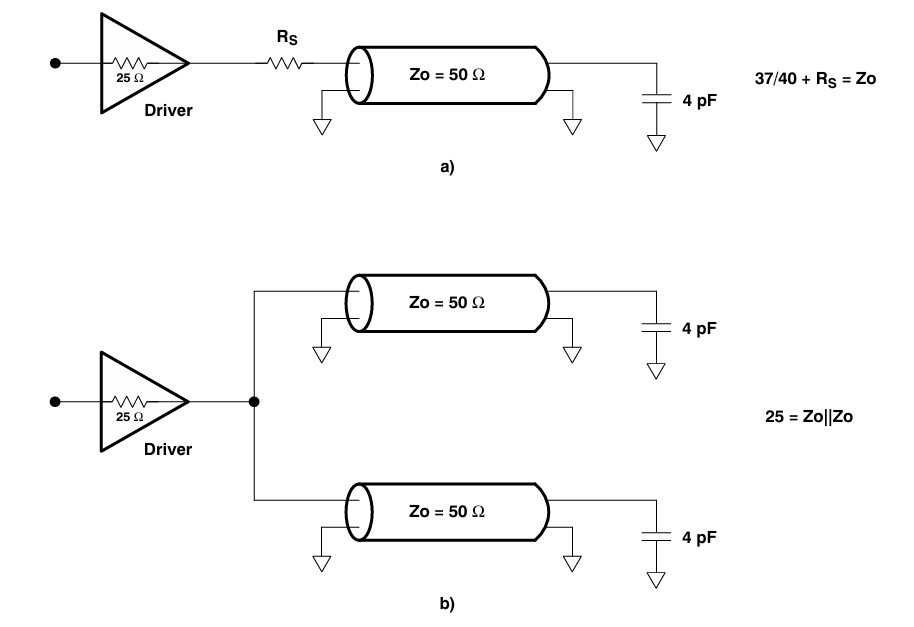
High speed digital signals traveling across a printed circuit board can behave like radio waves. If the signal is too strong or the copper trace is too long, the signal will hit the end of the wire and bounce back. This creates reflections and ringing that corrupt the data integrity.
To prevent this, I placed a 22 Ohm series resistor on both the TX and RX lines at the TELEME port. This electrical technique is known as source termination. The 22 Ohm resistor absorbs the reflected energy and slightly slows down the rising edge of the digital signal. This approach heavily reduces electromagnetic interference and guarantees that your telemetry data reaches the LoRa module with maximum clarity.
You can check on this website for an outstanding academic discussion regarding how termination resistors work in digital electronics: Texas Instruments Termination Guide.
PCB Routing: The Rules of High-Speed Data
Having the USBLC6-2P6 in your schematic is only 50 percent of the battle. The way you physically draw the copper traces on your PCB dictates whether the protection will actually work.
When laying out a Flight Controller, the USB data lines (D+ and D-) must be routed as a differential pair. This means the two copper traces must travel exactly parallel to each other, maintaining a strict 90 Ohm differential impedance. If you make one trace longer than the other, or if you space them incorrectly, the USB signal will bounce back and forth, causing your computer to say "USB Device Not Recognized."
Furthermore, the USBLC6-2P6 must be placed physically as close to the USB Type-C connector as humanly possible. If you place the protection diode near the microcontroller instead of the connector, the ESD spike will travel across the entire length of your circuit board, radiating massive electromagnetic interference into your gyroscopes and barometers before it finally gets clamped.
You must also never use a "via" (a hole that goes through the layers of the PCB) on the USB traces before they hit the protection diode. Vias add inductance, which slows down the clamping response time. The raw copper trace must go straight from the connector pin, into the diode pad, and then proceed to the MCU.
Drop a comment below if you want me to do a dedicated post on how to use your PCB layout software's impedance calculator to achieve the perfect 90 Ohm differential pair routing!
Hardware Defense Part 2: Taming the Noisy VBUS
Protecting the data communication lines ensures the brain of the drone can talk to the computer. But what about the power? We also need to carefully manage the 5V power coming from your computer cable, which is known on the schematic as VBUS.
Many people assume that the USB port on their expensive laptop outputs a perfectly clean, flat 5V DC signal. This is completely false. The 5V supplied by a standard PC motherboard or a cheap external USB hub is notoriously "dirty." It is generated by noisy switch-mode power supplies inside the computer, meaning the power is full of high-frequency noise, voltage ripples, and AC hum.
If we take this dirty 5V VBUS power and feed it directly into the Flight Controller's internal 3.3V Low Drop Out regulators, that noise does not just disappear. It bleeds straight through the regulator. This electrical noise will violently fluctuate the reference voltages used by the sensitive analog measurements of our gyros, accelerometers, and barometers. If you have ever plugged in your drone to Betaflight or ArduPilot and noticed your 3D model twitching randomly even though the drone is sitting perfectly still on your desk, dirty VBUS power is often the culprit!
The LC Pi-Filter Solution
To solve this noise problem and guarantee absolute stability, I designed a robust LC low-pass filter network specifically on the VBUS input line.
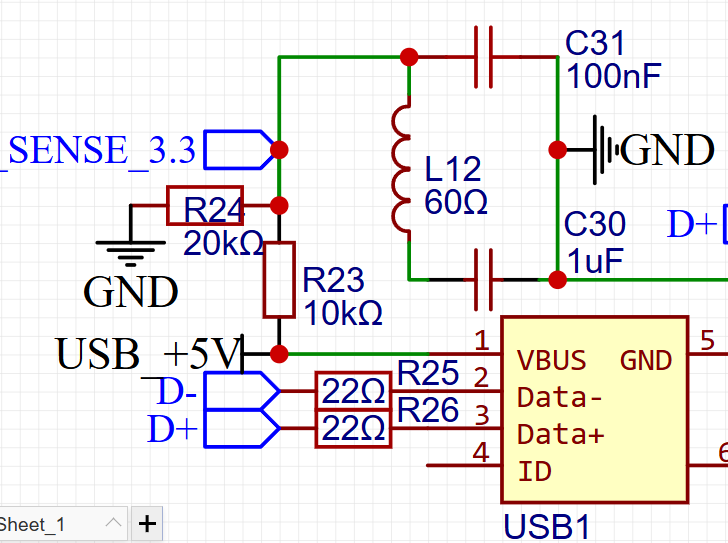
Before the raw 5V from the computer is allowed to reach the rest of the board (where it becomes the VBUS_IN net), it must pass through a gauntlet of components. The first component is an inductor, specifically a Ferrite Bead (labeled L1 on the schematic).
A ferrite bead is a fascinating component. At low frequencies (like pure DC power), it acts just like a normal piece of wire, allowing the 5V current to pass through freely. But at high frequencies (like the electrical noise generated by computer power supplies), the ferrite material actively resists the current. It literally absorbs the high-frequency electrical noise and safely dissipates it into the surrounding air as microscopic amounts of heat.
However, a ferrite bead alone is not enough. I combined this bead with two stages of capacitance. First, I placed a massive 10uF ceramic bulk capacitor. This acts as a localized energy reservoir, smoothing out any large voltage dips or low-frequency ripples from the computer. Second, I placed two 100nF ceramic decoupling capacitors directly adjacent to it. Because smaller capacitors have a lower Equivalent Series Resistance at high frequencies, the 100nF capacitors are perfectly tuned to absorb ultra-fast voltage spikes that the 10uF capacitor is too slow to catch.
Together, the Ferrite Bead, the 10uF capacitor, and the 100nF capacitors create an impenetrable LC filter. They take the chaotic, noisy power from your computer and transform it into a perfectly flat, clean, and safe 5V supply for the rest of your sensitive aviation hardware.
For an incredible visual explanation of how to design a robust USB hardware interface from scratch, including the math behind the TVS diodes and VBUS filtering we just discussed, you can see in this video from Phil's Lab on YouTube: https://youtu.be/W13HNsoHj7A?si=HAqM2yn2nMLlvtp2. He is a phenomenal resource for professional PCB design and watching him route these exact components is highly educational.
Every single time you plug your Flight Controller into your computer to flash new firmware, download blackbox logs, or tune your PID loops, you are introducing a massive electrical risk to your main microcontroller. In the era of modern USB Type-C connectors, this risk is greater than ever before. Today, I am going to show you exactly how I designed the USB interface block in my schematic to protect the brain of the drone using strict Electrostatic Discharge protection and advanced VBUS Filtering.
The Physics of Electrostatic Discharge
To truly understand why we need protective circuitry, we first must understand the invisible enemy we are fighting: Electrostatic Discharge, commonly referred to as ESD.
When you walk across a carpet in your workshop, slide out of a fabric chair, or even just handle the carbon fiber frame of your drone, your body acts like a giant capacitor. Through a process called the triboelectric effect, friction causes your body to build up a massive imbalance of static electricity. You might not feel it, but your fingertip can easily carry a localized charge of well over 10000 Volts.
When you reach out to plug that metal USB cable into your Flight Controller, that 10000 Volts looks for the easiest path to ground. Often, a microscopic spark will jump from your finger, travel through the metal shielding of the USB connector, and strike directly into the D+ and D- data lines of the microcontroller.
Because the USB data pins on modern silicon chips are incredibly sensitive—designed to read delicate signals operating at just 3.3V—this massive high-voltage transient will instantly blow a microscopic hole through the internal silicon layer. This permanently destroys the USB peripheral inside the chip. Your drone might still fly, but it will never communicate with a computer again.
For a highly trusted, academic explanation of how static discharge destroys modern semiconductors and how the Human Body Model is calculated, you can check on this website from Texas Instruments: System-Level ESD Protection Guide.
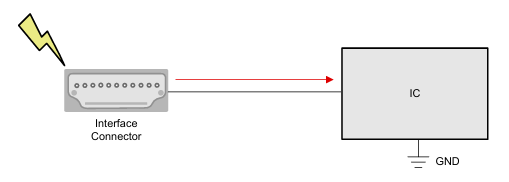
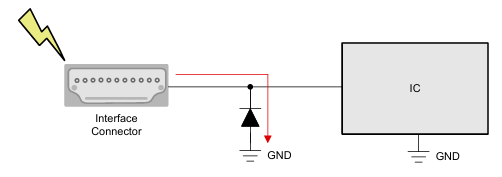
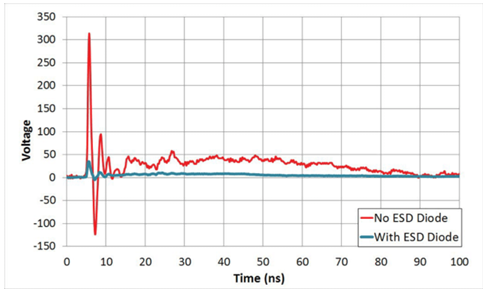
This images shown the massive, instantaneous spike in current that hits your board during an ESD event
The Anatomy of the Type-C Vulnerability
In the old days of drone building, we used Micro-USB connectors. While fragile, their internal pins were relatively far apart. Today, we use USB Type-C. Type-C is amazing for usability because it is reversible, but from a hardware design perspective, it is a nightmare.
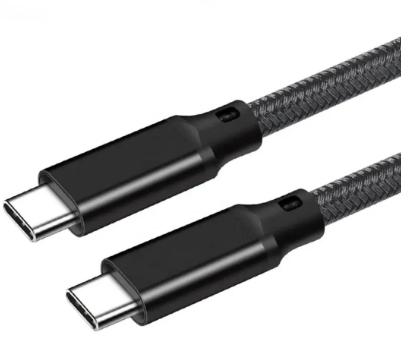
Modern USB Type-C receptacles feature 24 highly miniaturized pins packed into a very small footprint. Within this layout, the VBUS power pins, capable of delivering 5V to 20V in Power Delivery configurations, sit less than a millimeter from the highly sensitive data lines. If foreign debris enters the port or if a cable is inserted or removed at an improper angle, it creates a high risk of short-circuiting the power directly to the data pins. Without proper hardware protection, this event will result in severe, irreversible damage to the microcontroller.
Hardware Defense Part 1: Clamping the Spike with the USBLC6-2P6
To prevent these destructive voltage spikes from reaching the processor, we must place an invisible electrical shield right at the USB connector. We cannot just use normal diodes, because normal diodes are too slow. We need a component that reacts in nanoseconds.
In my Flight Controller schematic, I implemented a Transient Voltage Suppressor diode array. Specifically, I chose the absolute industry standard for this application: the USBLC6-2P6 from STMicroelectronics.
If you look at my design layout, this tiny 6-pin integrated circuit sits directly between the USB Type-C connector and the main MCU. It acts like a high-speed pressure relief valve. During normal operation, the USBLC6-2P6 has an incredibly low parasitic capacitance of around 1.2pF. This ultra-low capacitance means it is completely invisible to the high-frequency waves of the USB data stream, allowing our 480 Mbps high-speed signals to pass through without being distorted or slowed down.
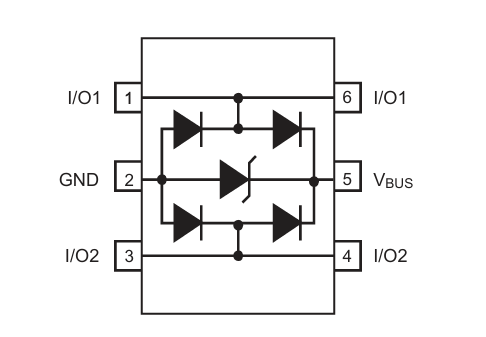
However, the absolute nanosecond a high-voltage ESD spike or a short-circuit surge hits the D+ or D- line, the internal avalanche diodes inside the USBLC6-2P6 wake up. They "clamp" down instantly, dropping their resistance to near zero. They act as a massive short circuit that safely grabs that 10000 Volts and redirects the energy straight into the Ground plane of the PCB, completely bypassing and saving the microcontroller.
You can download the official datasheet for this magnificent protective component directly from the manufacturer here: USBLC6-2P6 Datasheet.
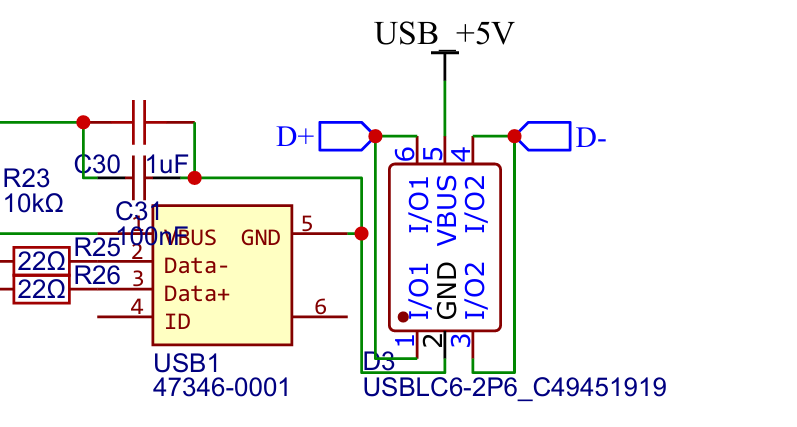
That images shown exactly how the internal diodes are cleverly routed to protect the I/O lines and dump the high voltage directly into the GND pin
Why Not Use the Internal Clock?
Modern microcontrollers come with a built-in High-Speed Internal (HSI) RC oscillator. It is tempting to just use this and save board space. However, the HSI is notoriously inaccurate. It typically has a tolerance of around 1% to 2%, and worse, it drifts significantly as the temperature of the chip changes.
If your drone is flying in hot weather, that 1% error can cause high-speed communication protocols like CAN Bus, USB, and fast UART telemetry to completely desync, leading to dropped packets or a crashed drone.
For a fundamental breakdown of how quartz crystals generate stable frequencies compared to internal RC circuits, you can check on this website: Electronics Tutorials: Quartz Crystal Oscillators.
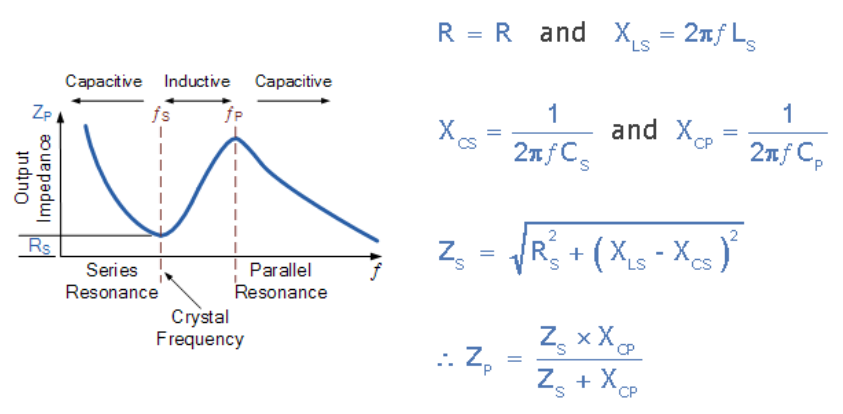
This images shown the exact, incredibly narrow resonance band that makes a quartz crystal so much more stable than an internal RC circuit
The 8MHz Crystal
To achieve the parts-per-million (ppm) accuracy required for high-speed protocols, we must use an external quartz crystal. In my Flight Controller schematic, I use a dedicated 25MHz crystal connected directly to the OSC_IN and OSC_OUT pins of the MCU.
According to the specific datasheet for the crystal I selected, it has a strict Load Capacitance (CL) requirement of 20pF to operate at exactly 25.000000 MHz.
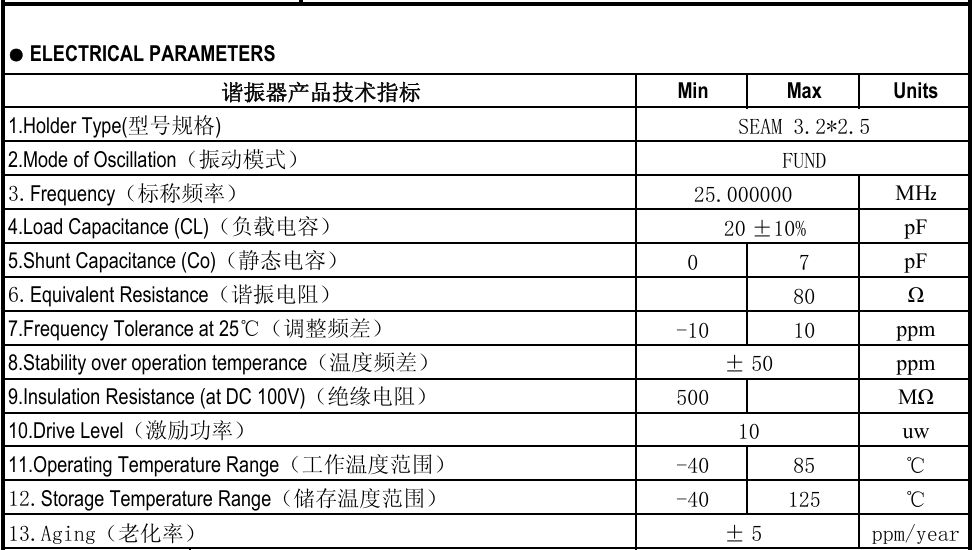
Why 30pF?
If you look closely at my schematic, you will see two small capacitors connecting each side of the crystal to Ground. These are "Load Capacitors." If these are the wrong value, your USB connection will likely fail to recognize the device.
How do we choose them? We calculate it!
The standard formula for calculating the external capacitors (C_ext) is:
C_ext = 2 * (CL - Cs)
"Cs" is the stray capacitance of your PCB traces and the MCU pins. For a standard, well-routed Flight Controller PCB, Cs is generally estimated to be 5pF.
Let's plug in our numbers:
C_ext = 2 * (20pF - 5pF)
C_ext = 2 * 15pF
C_ext = 30pF
Therefore, the mathematically perfect value for our load capacitors is 30pF.
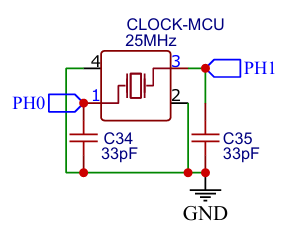
However, in my initial schematic draft, I utilized 33pF capacitors. Is this wrong? Not necessarily! If we reverse the math, using 33pF capacitors means the circuit assumes a stray capacitance of exactly 3.5pF instead of 5pF. If your PCB traces between the MCU and the crystal are extremely short and well-optimized, 33pF will work flawlessly. But for the safest, sticking to the standard calculated 30pF is best practice!
STMicroelectronics AN2867
If you are designing a Flight Controller using an STM32 MCU, you cannot just guess these values or layout techniques. You must design the schematic according to the manufacturer's strict specifications.
The absolute best resource for this is the official STMicroelectronics Application Note AN2867: Oscillator design guide for STM8AF/AL/S, STM32 MCUs and MPUs. It dictates exactly how to select the crystal, verify the ESR, and route the PCB traces.
You can download and read the official document directly from STMicroelectronics here: STMicroelectronics AN2867.
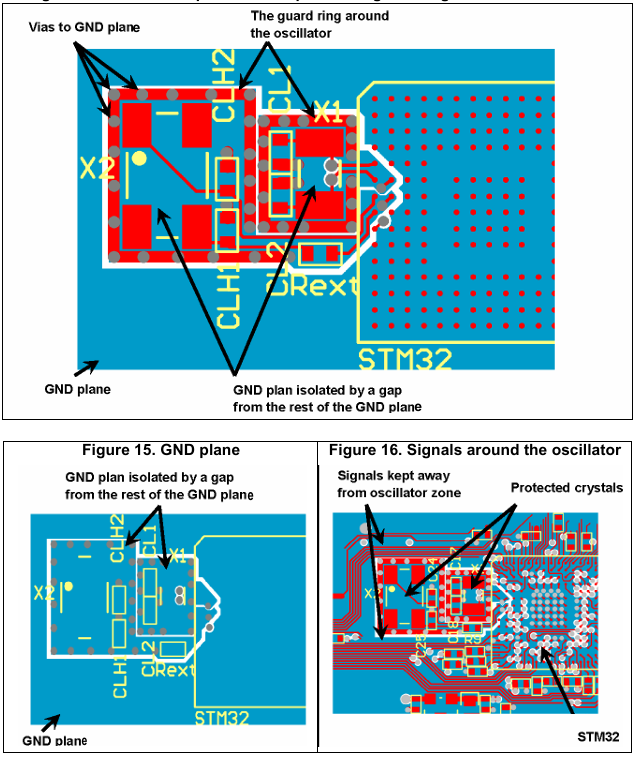
Software Integration
Once the hardware is designed correctly, we tell our firmware to ignore the internal clock. In ArduPilot or Betaflight hardware definition files, we explicitly define the HSE frequency as 25.000.000 Hz. The software then configures the internal Phase-Locked Loop (PLL) multipliers to boost that 8MHz signal up to the MCU's maximum processing speed!
For complex custom missions like a UAV payload dropping system integrated with LoRa or GSM tracking modules—we need physical, reliable control over external hardware. Today, I am going to show you how I integrated Safety Switches and Relay Drivers into my Flight Controller schematic using specific components like the 1N4148W diode, ensuring maximum safety and mission capability.
Part 1: The Safety Switch (Hardware Arming)
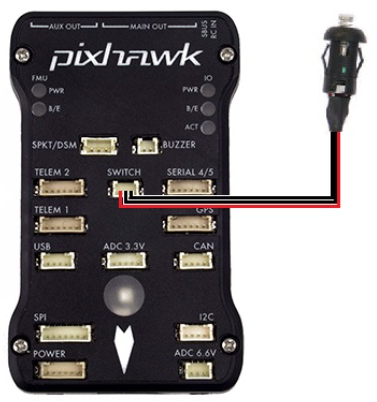
Software arming via your radio transmitter is great, but when you have a large drone carrying a heavy payload, you need a physical, hardware-level interrupt. A hardware safety switch prevents the PWM signals from reaching the motors until you physically press a button on the drone, ensuring the propellers cannot spin while you are handling the aircraft.
In my Flight Controller schematic, the safety switch circuit is connected via a secure JST-style SM03B connector. To ensure the physical button signal sent to the MCU is perfectly clean, I designed a hardware debouncing circuit. The signal pin is pulled up using a 10kOhm resistor (R51), and we add a 100nF capacitor (C64) in parallel to ground. This simple 100nF capacitor acts as a low-pass filter, ensuring the MCU reads a single clean press instead of a noisy, bouncing electrical signal.
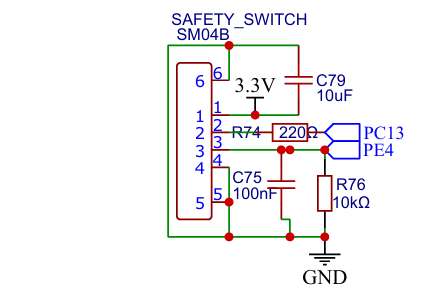
The image shown of my schematic that I just provided, that showing the SAFETY SWITCH section. This images shown exactly how the debouncing capacitor and pull-up resistor are routed to the SM03B connector
You can check on this website for the exact ArduPilot hardware implementation of this switch: ArduPilot Safety Switch Documentation.
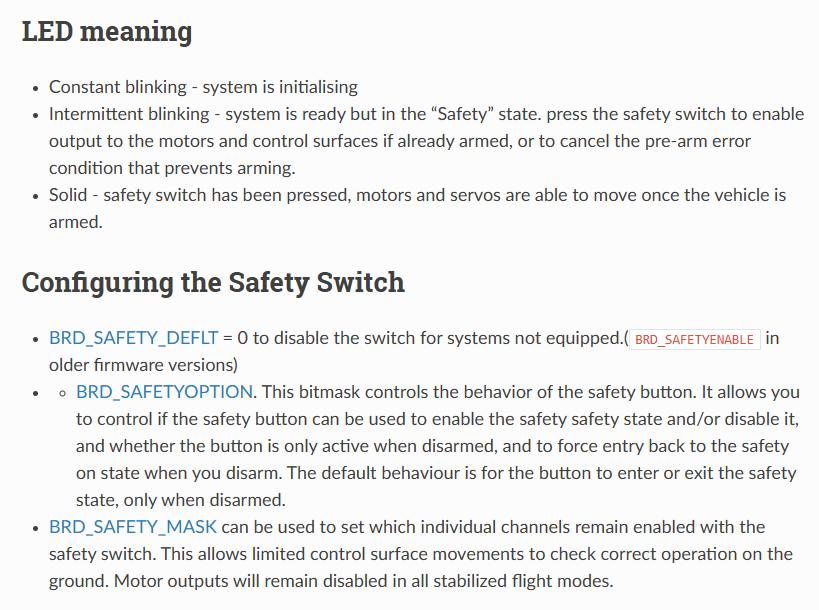
LED Meaning
- Constant blinking - system is initialising
- Intermittent blinking - system is ready but in the “Safety” state. press the safety switch to enable output to the motors and control surfaces if already armed, or to cancel the pre-arm error condition that prevents arming.
- Solid - safety switch has been pressed, motors and servos are able to move once the vehicle is armed.
Configure the Safety Switch
- BRD_SAFETY_DEFLT = 0 to disable the switch for systems not equipped.(
<span class="pre">BRD_SAFETYENABLE</span>in older firmware versions) -
- BRD_SAFETYOPTION. This bitmask controls the behavior of the safety button. It allows you to control if the safety button can be used to enable the safety safety state and/or disable it, and whether the button is only active when disarmed, and to force entry back to the safety on state when you disarm. The default behaviour is for the button to enter or exit the safety state, only when disarmed.
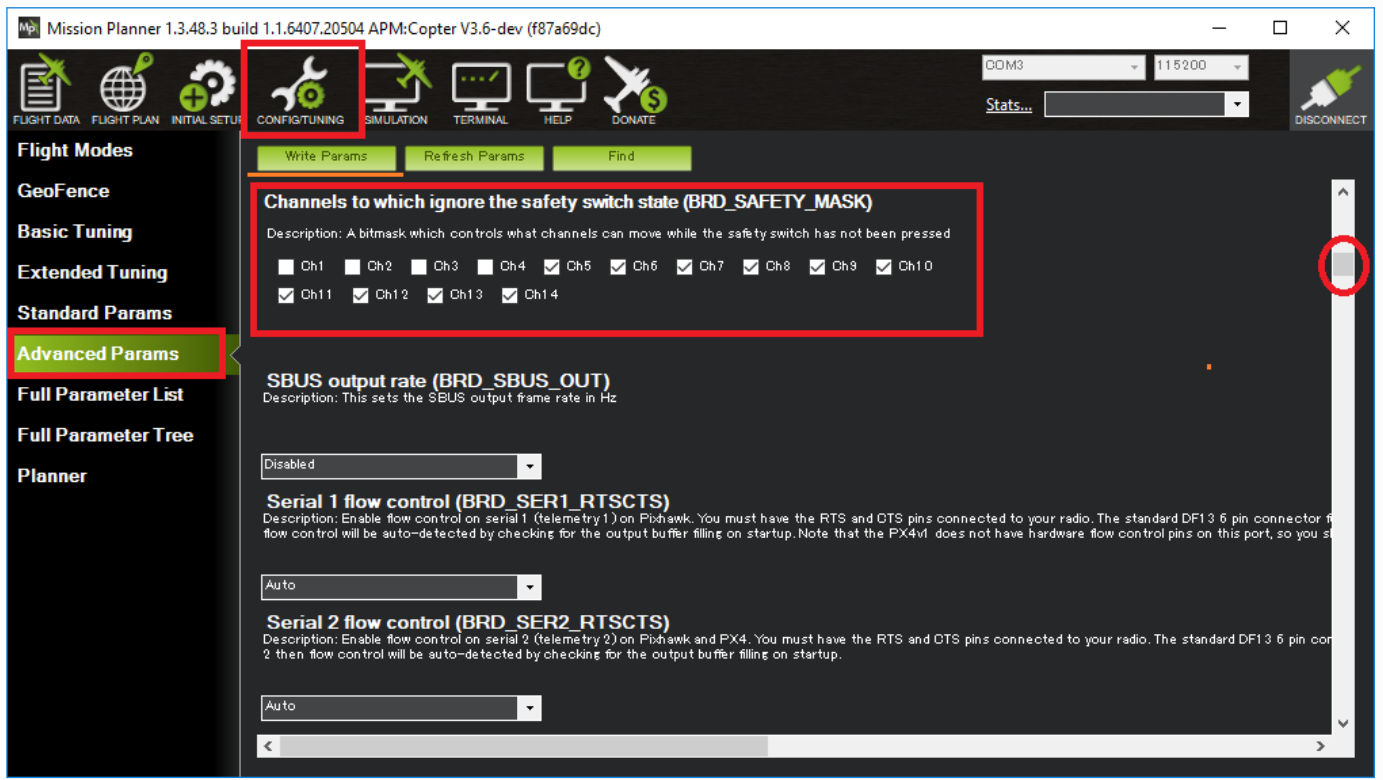
- BRD_SAFETY_MASK can be used to set which individual channels remain enabled with the safety switch. This allows limited control surface movements to check correct operation on the ground. Motor outputs will remain disabled in all stabilized flight modes.
Part 2: The Relay Driver (Actuating the Mission)
If we want to trigger a payload drop mechanism, we need a relay. The main MCU operates at 3.3V and outputs only a few milliamps. It physically cannot drive a mechanical relay coil directly without burning out the pin.
To solve this, I designed an isolated Relay Driver circuit. As seen in my schematic, we use a transistor (Q2 and Q3) as a digital switch. When the MCU sends a HIGH signal to the transistor's gate or base, it turns on, allowing a larger 5V current to flow through the relay coil and activate our payload.
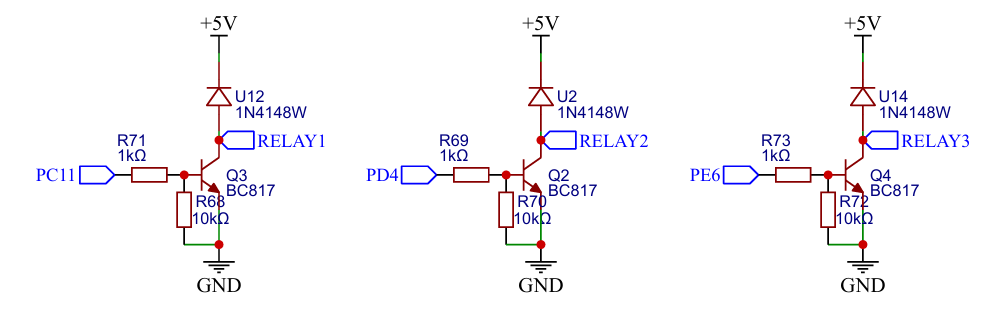
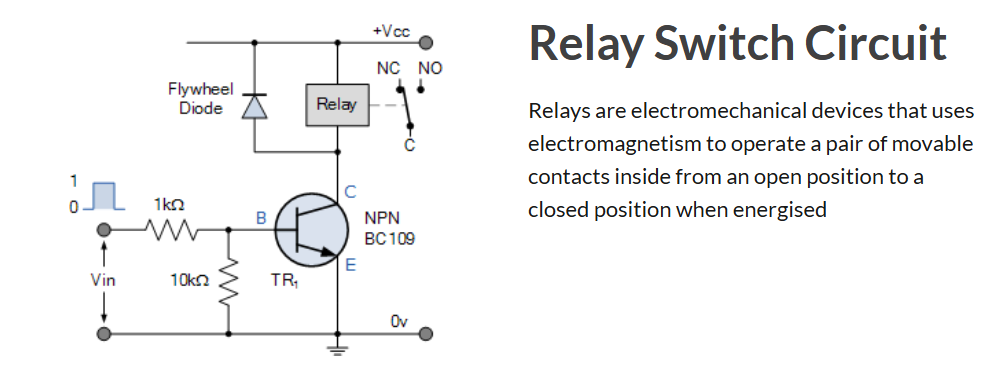
One absolutely critical component you will see in my schematic is the 1N4148W flyback diode (labeled D2 and D3). When the relay coil turns off, the collapsing magnetic field generates a massive high-voltage spike that will travel backwards and destroy the transistor or MCU. We place the 1N4148W diode in reverse-bias directly across the relay coil.
If you check a standard 1N4148W datasheet, you will see it has an ultra-fast reverse recovery time of just 4ns! This means it acts instantly to clamp and safely dissipate the destructive energy before it can damage the system.
You can check on this website for an amazing, highly trusted breakdown of how this transistor logic works: Electronics Tutorials: Relay Switch Circuit.
To see exactly what happens to a circuit when you forget this crucial component, you can see in this video from YouTube: Flyback Diodes in Relay Circuits Explained.
Part 3: Software Configuration for Missions
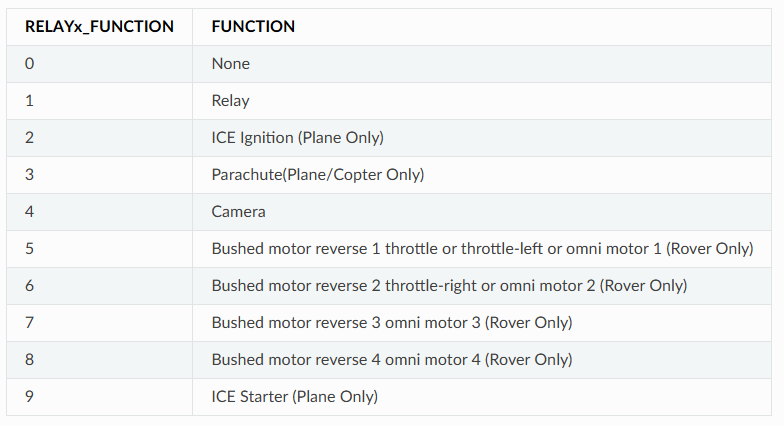
In ArduPilot, we map the MCU pin connected to our transistor as a "Relay Pin." Once mapped, we can assign an RC channel (Auxiliary Switch) on our radio transmitter to trigger this relay in mid-air. Even better, for autonomous payload dropping missions, we can insert a DO_SET_RELAY command directly into our GPS waypoint mission. The drone will fly to the target coordinate and automatically trigger the hardware we just designed!
You can check on this website for the official documentation on setting this up: ArduPilot Relay Switch Documentation.
When designing hardware for custom drones or autonomous vehicles, we often focus on the "brain" of the system, the main Microcontroller Unit (MCU). But no matter how fast your MCU is, it will completely fail if the power supplied to it is dirty or unstable.
Today, we are going to talk about one of the most critical power design rules in drone hardware: physically separating the "thinking" from the "moving" by securing the main MCU with a Dedicated Servo Rail.
Back-EMF and Voltage Spikes
In a drone system, the flight controller must constantly command motors (via ESCs) and physical servos. These are heavy inductive loads. When a servo motor moves rapidly, abruptly stops, or reverses direction, the magnetic coils inside it act like a generator. They shoot a high-voltage surge of current back into the power line. This is known as Back-EMF (Electromotive Force).
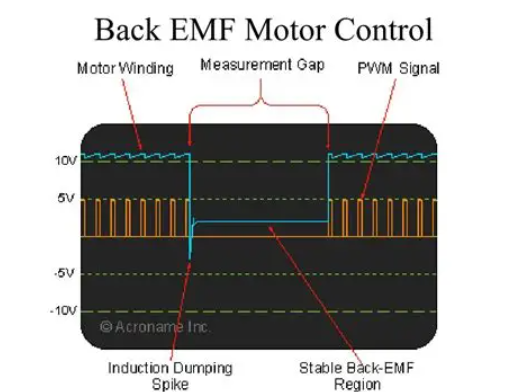
If your delicate 3.3V or 5V MCU power rail is directly connected to the same power line as your servos, these sudden voltage spikes can easily reach 8V or more. When this high-voltage transient hits the MCU, it will either instantly reset (causing a mid-air brownout) or permanently destroy the silicon.
For a deep technical explanation of how motor inductance causes these destructive spikes, you can check on this website from Pololu: Understanding Destructive LC Voltage Spikes.
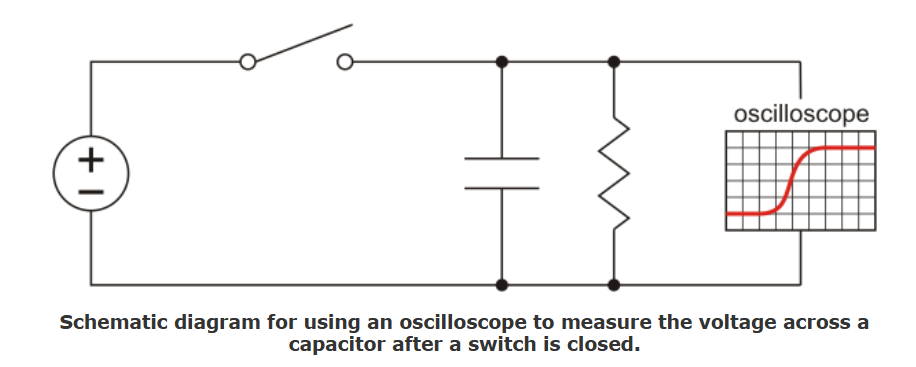
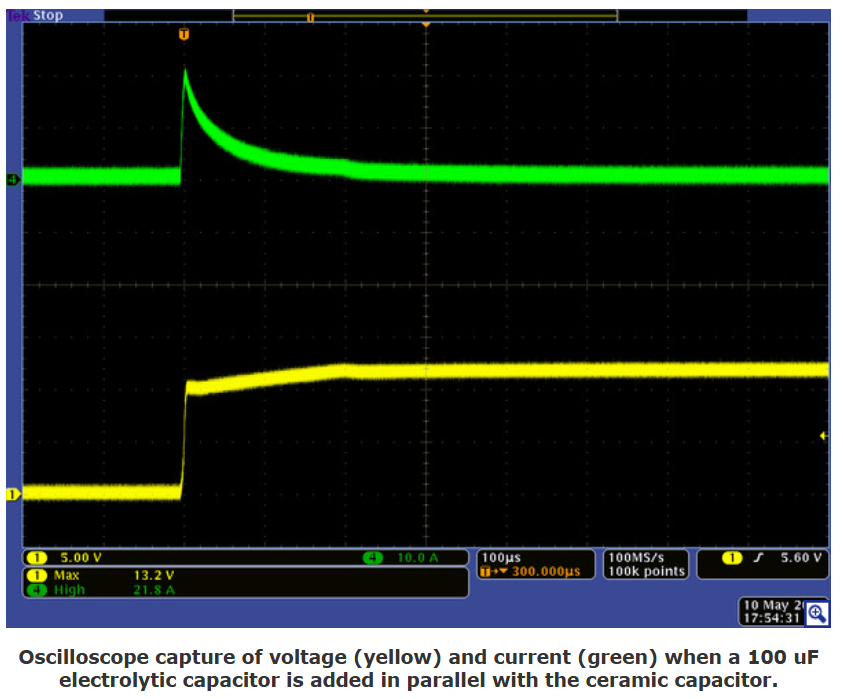
This image shown exactly how a stable 5V line can violently spike up to nearly 12V when an inductive load is connected!
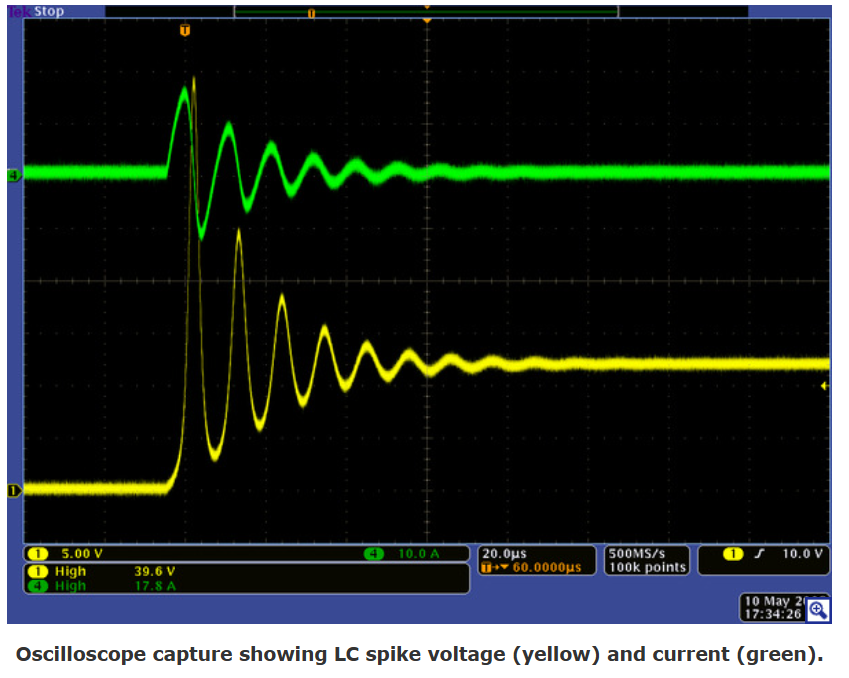
The large capacitor prevents the voltage from changing quite as quickly, yet its high ESR prevents it from drawing as much initial current. Here is the result when we added a 100 uF electrolytic capacitor in parallel with our 10 uF test capacitor:
The Schematic Solution: The Dedicated Servo Rail
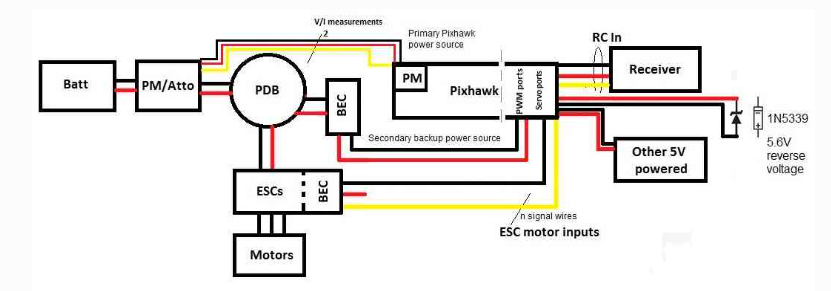
To protect our Flight Controller, we use a strategy called "Power Isolation." If you look at the design of my Flight Controller, the power supply for the MCU (often labeled VCC) and the power supply for the PWM outputs (the Servo Rail) are completely separated.
They do not share a 5V source.
- The MCU Power: The brain gets its clean 5V from our heavily filtered, dual-redundant power module inputs.
- The Servo Power: The servos get their power from an external BEC (Battery Eliminator Circuit) provided by the ESC or a standalone regulator, which plugs directly into the Servo Rail headers.
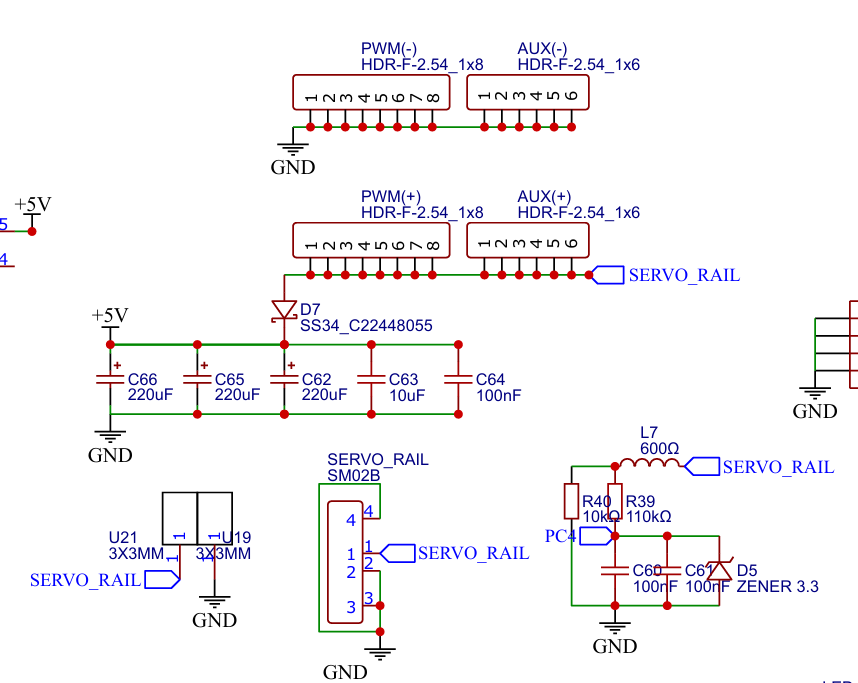
This is a cropping the "SERVO RAIL" and PWM output pin headers from my Flight Controller schematic. The 5V line on these pins is completely isolated from the MCU's 3.3V and 5V logic rails.
By completely separating the positive voltage traces on the PCB, any Back-EMF spikes generated by the servos stay trapped on the Servo Rail. The only things the MCU and the servos share are the PWM signal wires and the Ground Reference (GND).
Managing Spikes
Even though the MCU is isolated, we still don't want massive voltage spikes bouncing around our Servo Rail, as they can damage other connected peripherals.
In professional hardware design, we mitigate this by adding protection components directly to the power rails. For my Flight Controller designs, it is standard practice to place heavy filtering near the power inputs, such as a large electrolytic capacitor combined with smaller ceramic capacitors (like a 10uF and 100nF) placed close to the active components to absorb high-frequency noise.
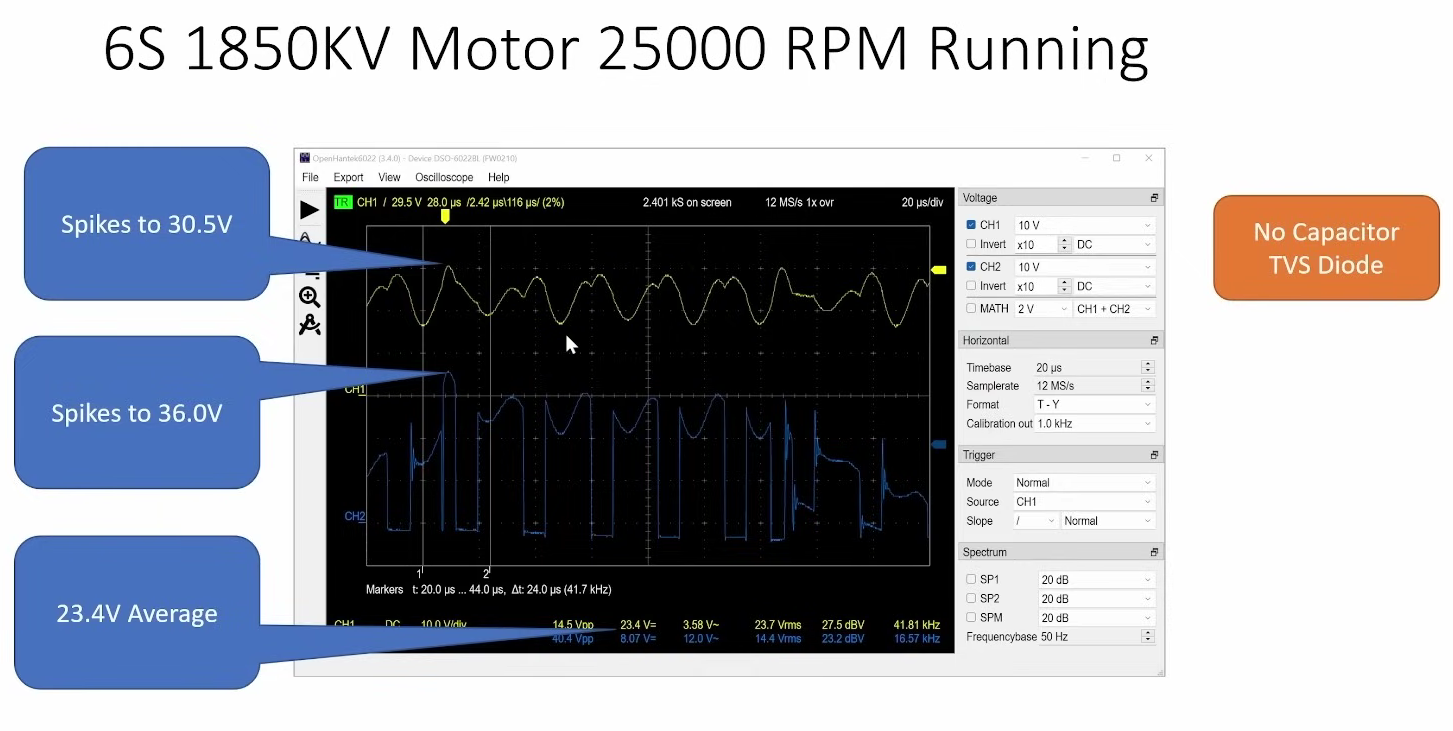
For extreme protection, aerospace and racing drones use TVS (Transient Voltage Suppression) diodes. These diodes act like a pressure relief valve, instantly clamping any voltage spike that exceeds a safe threshold.
You can see an incredibly detailed hardware test of how these components protect your drone in this video from Chris Rosser on YouTube: Protect Yourself from ESC Voltage Spikes: Testing Capacitors and TVS Diodes. He hooks up an oscilloscope to a live drone and proves exactly why we need this hardware!
Have you ever fried a flight controller because you plugged a servo into the wrong rail? Drop a comment below and share your hardware disaster stories so we can learn from them!
ArduPilot Standards: Wiring It Safely
This hardware isolation strategy is so critical that major firmware platforms like ArduPilot strictly mandate it in their official documentation. ArduPilot software expects the hardware designer to separate these power domains.
You can check on this website for the official ArduPilot hardware wiring guidelines: Powering the Pixhawk.
The block diagram below synthesizes an overview of Pixhawk’s power and ESC wiring. In this diagram, a 3DR power module (or equivalent device) powers Pixhawk through its power port (primary source). One power source is enough but obviously not redundant if the power module fails to power this primary source. Therefore the diagram adds a second backup power source via a 5V BEC that wires to Pixhawk’s output servo rail. If the primary source fails, Pixhawk will automatically switch to this second power source.